News · Tech

Eka Robotics raises US$150M at a US$1.45B valuation for robots that grip by feel

Eka Robotics, founded by MIT professor Pulkit Agrawal and former Google DeepMind researcher Tuomas Haarnoja, has raised a US$150 million Series A led by a16z and F-Prime. Its vision-force-action model, trained mostly in simulation, uses force feedback from a custom gripper and picks about 1,500 objects an hour in Eka's lab tests, about 2.5 times a person's rate.
Eka RoboticsRoboticsManipulationReinforcement learninga16zFunding

Eka Robotics has raised a US$150 million Series A led by Andreessen Horowitz and F-Prime, for a robot that does what most robots still struggle with: picking things up by feel[1]. TechCrunch reports the round values the company at US$1.45 billion post-money[2].

The startup was founded by MIT professor Pulkit Agrawal and Tuomas Haarnoja, a former Google DeepMind researcher; the two first met as graduate students at UC Berkeley[2]. Seed leads Obvious Ventures and E14 Fund, which co-led Eka's seed round in May 2025, came back for the round, alongside MFV Partners, Bison Ventures, Glasswing Ventures, Samsung Next and several Fortune 500 strategic investors[1][4].

01 / 04

Force, not just vision

Most robot foundation models today are vision-language-action models: they look, read an instruction and move. Eka's is a vision-force-action model. It combines camera input with force feedback from a custom gripper, so a grasp that starts to slip can be corrected and resistance during an insertion changes the robot's motion instead of throwing an error[3].

"Vision tells you roughly where the object is, what the pose is, but the actual grabbing, the actual searching is happening through forces," Agrawal told TechCrunch[2].

The other bet is how it is trained. Rather than relying on hours of human demonstrations, Eka uses reinforcement learning in a physics simulator, which it says generates thousands of hours of robot experience in minutes, then transfers that to real hardware[1]. It compares the approach to AlphaZero, which reached superhuman play in chess and Go without human data.

02 / 04

The numbers

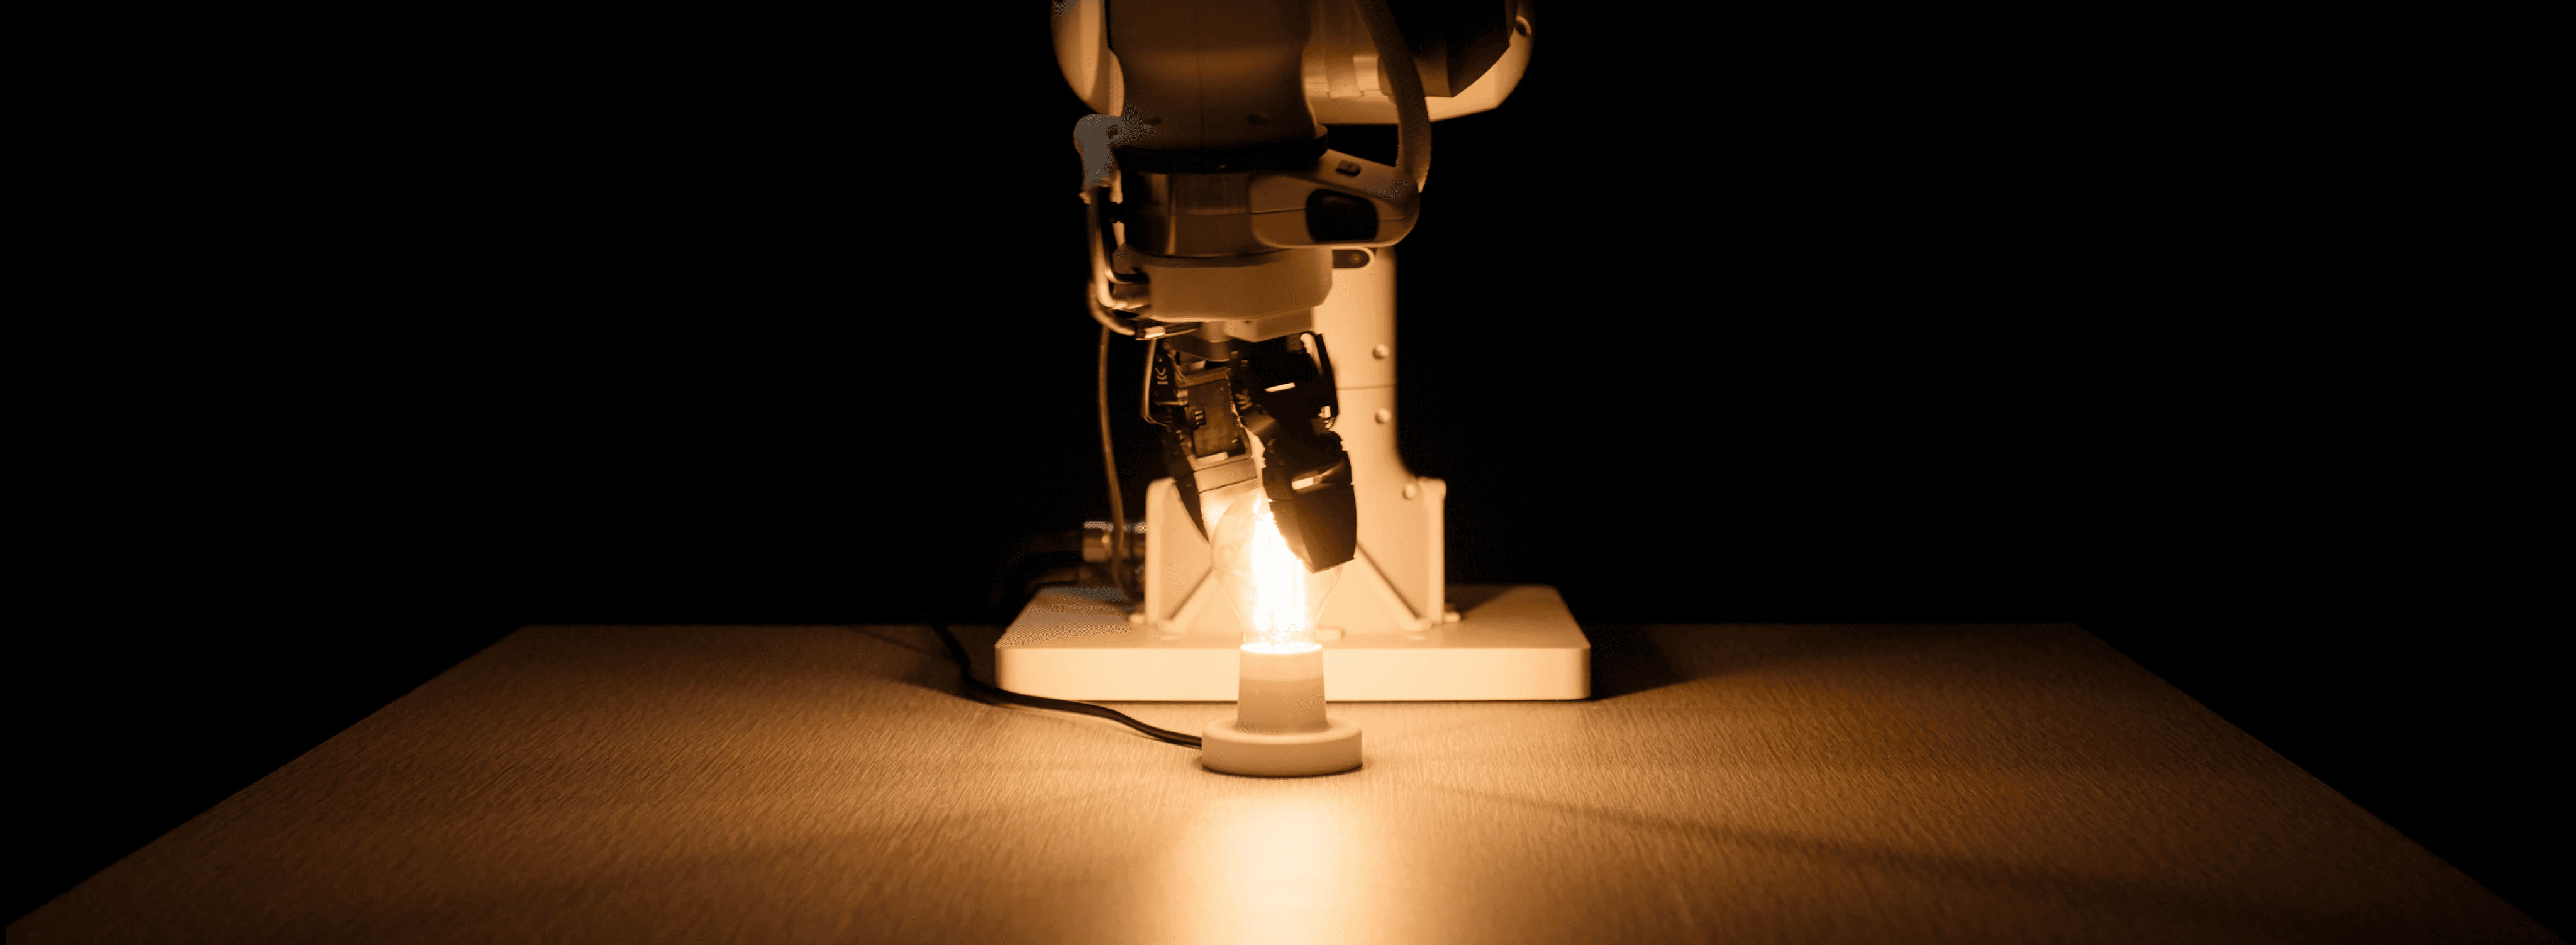
Eka says its robots pick a wide variety of objects outside their training distribution at about 1,500 operations an hour, roughly two and a half times a human baseline of about 600, and that the same robot can screw in a light bulb and insert wires[1]. TechCrunch adds that the objects weigh up to 1 kg and that Eka reports grasp success above 95%[2]. a16z is careful to say those are laboratory induction and bin-picking results, and that "sustaining that performance through full production shifts is the next test"[3].

Outside roboticists who have seen it are impressed. University of Illinois professor Kris Hauser told TechCrunch the robot "was able to adapt to a large number of different objects without retraining"[2]. Obvious Ventures says the robots work without safety cages and are gentle enough to take a single raspberry from a child's hand[4].

03 / 04

From lab to line

Eka is running pilots with industrial customers in two areas, pick-and-place and wire handling, but hasn't named them[2]. Its gripper costs under US$1,000 and is rated for 5 million duty cycles; Agrawal says the goal is the 20 million cycles expected of standard industrial arms[2]. The company says the money will go into extending the model to more tasks and speeding up deployments[1].

04 / 04

Why it matters

Dexterous handling is the gap between today's demo robots and ones that earn their keep on a factory floor. Large language models can increasingly plan what a robot should do; Eka is betting the hard part is the last millimetre of actually doing it, and that simulation plus touch gets there faster than collecting ever more human video. The open questions are the ones Hauser raises: whether it runs for a year on a real line without breaking, and how far it generalises beyond pick-and-place[2].

FAQ

Questions, answered.

01

What is Eka Robotics?

Eka Robotics is a robotics startup founded by MIT professor Pulkit Agrawal and former Google DeepMind researcher Tuomas Haarnoja, which raised its seed round in May 2025. It builds a manipulation system made of a force-sensing robotic gripper and a foundation model that controls it, aimed at picking, placing and handling objects in factories and warehouses.

02

How much did it raise, and from whom?

Eka announced a US$150 million Series A on 20 October 2026, led by Andreessen Horowitz (a16z) and F-Prime, the venture fund affiliated with Fidelity's parent FMR. Seed leads Obvious Ventures and E14 Fund joined again, along with MFV Partners, Bison Ventures, Glasswing Ventures, Samsung Next and several unnamed Fortune 500 strategic investors. TechCrunch reports a US$1.45 billion post-money valuation.

03

What is a vision-force-action model?

Most robot foundation models are vision-language-action models, which map camera images and instructions to movements. Eka's vision-force-action (VFA) model also takes force feedback from its gripper, so the robot can feel slip, contact and resistance and adjust mid-grasp. Eka trains it with reinforcement learning in a physics simulator, where it says it can generate thousands of hours of robot experience in minutes.

04

How fast is it?

Eka says its robots pick a wide range of objects outside their training data at about 1,500 operations an hour, roughly 2.5 times a human baseline of about 600. TechCrunch reports the objects weigh up to 1 kg and that Eka says grasps succeed more than 95% of the time. a16z notes these are laboratory induction and bin-picking results.

05

Is it in real factories yet?

Not at scale. TechCrunch reports Eka is running undisclosed pilots with industrial customers in pick-and-place and wire handling. Its gripper costs under US$1,000 and is rated for 5 million duty cycles, against the 20 million cycles typical of industrial arms, and Eka says the new funding goes toward more tasks and customer deployments.